An independent research workshop designing multi-agent AI consensus architectures, underwater marine robotics, competition mechatronics, and green changemaker networks.
Meeting the architect behind DSIndieAI's hardware, software, and research innovations.
Founder & Lead Engineer
Currently a student at the American International School of Budapest (AISB), set to graduate in 2030. He alone founded DSIndieAI, authoring multi-agent AI frameworks, competition robotics builds, and eco-tech social platforms.
One must not forget the pioneering spirit, and mindset.
The Changers Network — a dedicated social network and collaborative ecosystem for student changemakers — has officially received grant funding from the American International School of Budapest (AISB) along with strategic promotional support from Inspire Citizens.
Direct institutional backing from the American International School of Budapest supporting backend infrastructure, database hosting, and community deployment.
Global promotional outreach and community building support in alignment with global citizenship education and youth action initiatives.
Multi-Client App Architecture
Bridging international schools, global changemaker networks, local Budapest eco-brands, and sustainable initiatives.
Global educational collaboration supporting youth changemakers, providing promotional backing for the Changers Network, and driving sustainable action curricula.
Collaboration with a local boutique sustainable fashion brand in Budapest, blending technology, upcycled media outreach, and eco-friendly apparel design.
Grant funder and primary campus testbed for DSIndieAI innovations including StudyHub, Cap Collective IoT bins, and student workflow automation.
Local mall partnership in Nagykovácsi village deploying physical plastic bottle cap collection bins connected directly to the Cap Collective circular recycling telemetry.
Custom omnidirectional drive robots, underwater fluid simulators, and award-winning FIRST LEGO League mechatronic builds.
Custom underwater Remotely Operated Vehicle (ROV) paired with a high-fidelity 3D hydrodynamics software physics simulator built in C++/JS to model ballast, thruster dynamics, and underwater buoyancy for competition readiness.
Custom-engineered Kiwi drive (3-wheel omnidirectional) mechatronic robot platform featuring vector kinematics, micro-controller motor synchronization, ultrasonic telemetry, and wireless remote control.
Award-winning FIRST LEGO League robot engineered for structural durability, modular attachment switching, and precise gear ratio power transmission. Honored with the prestigious FLL Build Award for superior mechanical design.
Competition robotics build for the FIRST LEGO League MASTERPIECE season. Features dual gyro navigation sensors, color line-following routines, and multi-mission modular arm mechanisms.
Robotics and innovation solution for the FLL SUBMERGED season exploring ocean science, oceanographic exploration robotics, autonomous coral reef restoration mechanisms, and aquatic mission solvers.
# Multi-LLM Debate: Heterogeneous Model Collaboration for Improved Reasoning
// Authors: David I.K. (DSIndieAI)
ABSTRACT: We present Multi-LLM Debate, orchestrating solver, critic, verifier, and synthesizer agents to boost GSM8K math accuracy to 80% (+26.7% overall).
Key Benchmarks:
• Single Model: 0% - 20% Accuracy
• 3-Model Debate: 26.7% - 80.0% Accuracy
• Cost: $0 (Free-tier Groq/Gemini API mesh)
Authoring original research in multi-agent LLM consensus topologies and sustainable, energy-efficient AI hardware execution.
Research paper introducing structured multi-turn debate among heterogeneous LLMs (solver, critic, verifier, synthesizer) operating on a free-tier API mesh. Proves a +26.7% reasoning accuracy lift over single models.
Investigation into energy-efficient AI system designs, carbon-aware model scheduling, low-bit quantized edge inference, and minimizing the environmental footprint of LLM deployments.
Recognised on the global stage at ReverieHacks 2026, and on the water in a local SeaPerch tournament.
Winner in a fully virtual, three-week hackathon run entirely by high school organisers, open worldwide across six tracks.
Won the Datathon track, where teams apply machine learning and data science to real datasets and surface patterns to solve a problem.
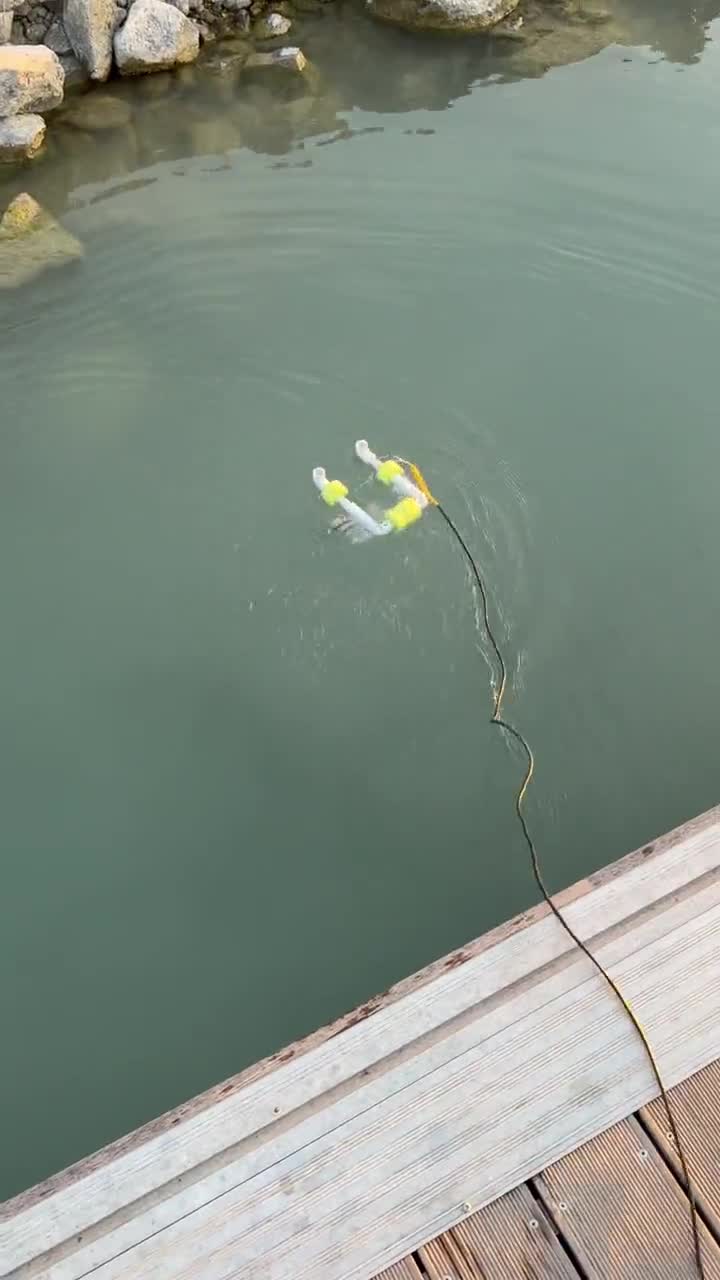
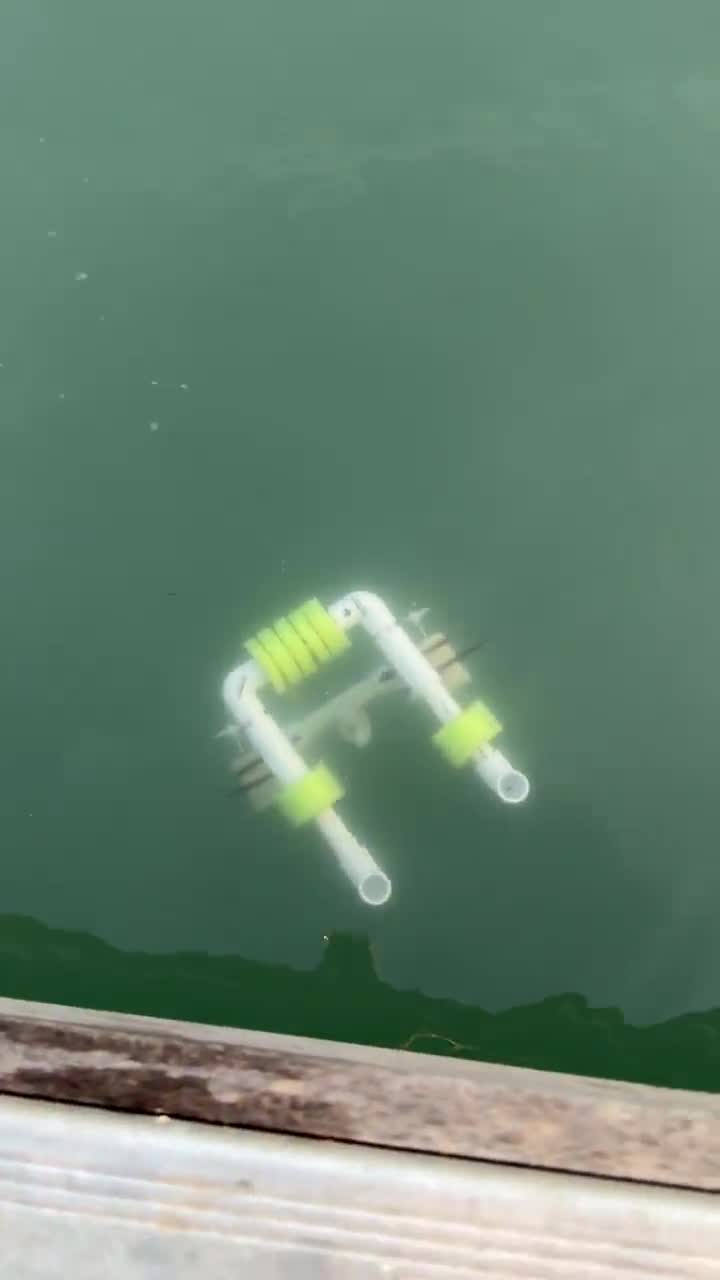
Took first place at a local SeaPerch underwater robotics tournament with the custom ROV — the same platform whose build log is published below.
ReverieHacks figures published on the event's own impact page. SeaPerch result is a local event.
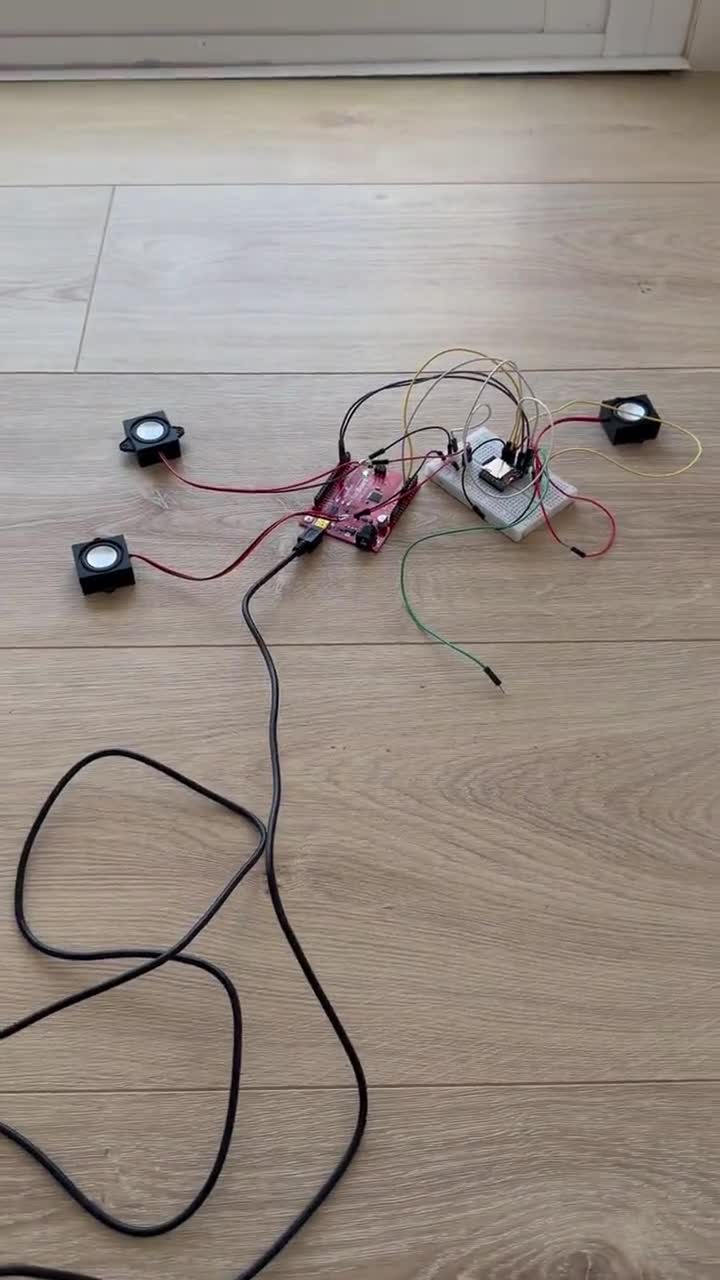
Footage from the build: breadboard assembly, the live force and power telemetry readout, the finished chassis, and pool trials. Tap any clip to play.
0:12
ROV AFLOAT
0:12
UNDERWAY
0:12
4 THRUSTERS
0:03
LIVE TELEMETRY
0:08
ARDUINO NANO
0:11
DISPLAY MODULE
0:04
SIGNAL ROUTING
0:12
POWERED UP
PHOTO
PHOTO
8 clips and 2 photographs from the SeaPerch build and pool trials. Clips are trimmed and compressed for the web.
Click any project card or icon for a full overview with live links, features, and the source repository.
46 projects indexed
Evolving from standalone utilities to a globally funded research and mechatronics network.
Launch of TobiAI, StudyHub, and core web platform suite.
MultiLLM consensus paper, SeaPerch ROV simulator, LeKiwi robot, and FLL Unearthed Build Award.
AISB grant execution, Inspire Citizens promotional rollout, and Euphoria Clothing Budapest collab.
ESP32 IoT sensor networks, micro-controller edge AI, and Cap Collective bin expansions.
DSIndieAI is expanding. We are seeking passionate collaborators, research editors, content creators, and codebase checkers.
Identifies real-world problems that can be solved by the organization, formulates strategic insights, and maps out actionable steps for project expansion.
Edits, verifies, and co-authors academic papers, research documentations, and experiment write-ups closely alongside the founder.
Manages the organization's official YouTube channel, creates educational visual media, and drives media production for Learning Fans.
Monitors database health, codebase integrity, multi-repository stability, and ensures continuous system hygiene across deployments.
Connect directly for research partnerships, robotics inquiries, or open roles.
“The Monado! It burns away the face of evil!” — Shulk, Colony 9
The city on KOHAN where it began. A single sword fell from the sky, and one boy decided to pick it up.
Five thousand years on, the sea swallowed everything and the world was renamed. The Mechon never stopped.
Defend the Elpys against Mechon incursions across the Pseudos-Capital. Field data compiled by Elma.